|
| | M5StackUnitBldc (ControlMode mode, Direction initial_direction, MotorModel model, uint8_t pole_pairs, bool save_to_flash) |
| |
| void | setup () override |
| |
| void | update () override |
| |
| void | dump_config () override |
| |
| void | set_pid (int32_t p, int32_t i, int32_t d) |
| | PID gains as the device stores them, each multiplied by 100.
|
| |
| | SUB_SENSOR (rpm) SUB_SENSOR(frequency) SUB_TEXT_SENSOR(status) SUB_NUMBER(command) void control_command(float value) |
| | The PWM duty number in open loop, the target RPM number in closed loop.
|
| |
| | SUB_SELECT (direction) void control_direction(size_t index) |
| |
| bool | write_command (float value) |
| | Send the PWM duty (open loop) or target RPM (closed loop).
|
| |
| bool | write_direction (Direction direction) |
| |
| | I2CDevice ()=default |
| | we use the C++ default constructor
|
| |
| void | set_i2c_address (uint8_t address) |
| | We store the address of the device on the bus.
|
| |
| uint8_t | get_i2c_address () const |
| | Returns the I2C address of the object.
|
| |
| void | set_i2c_bus (I2CBus *bus) |
| | we store the pointer to the I2CBus to use
|
| |
| I2CRegister | reg (uint8_t a_register) |
| | calls the I2CRegister constructor
|
| |
| I2CRegister16 | reg16 (uint16_t a_register) |
| | calls the I2CRegister16 constructor
|
| |
| ErrorCode | read (uint8_t *data, size_t len) const |
| | reads an array of bytes from the device using an I2CBus
|
| |
| ErrorCode | read_register (uint8_t a_register, uint8_t *data, size_t len) |
| | reads an array of bytes from a specific register in the I²C device
|
| |
| ErrorCode | read_register16 (uint16_t a_register, uint8_t *data, size_t len) |
| | reads an array of bytes from a specific register in the I²C device
|
| |
| ErrorCode | write (const uint8_t *data, size_t len) const |
| | writes an array of bytes to a device using an I2CBus
|
| |
| ErrorCode | write_read (const uint8_t *write_data, size_t write_len, uint8_t *read_data, size_t read_len) const |
| | writes an array of bytes to a device, then reads an array, as a single transaction
|
| |
| ErrorCode | write_register (uint8_t a_register, const uint8_t *data, size_t len) const |
| | writes an array of bytes to a specific register in the I²C device
|
| |
| ErrorCode | write_register16 (uint16_t a_register, const uint8_t *data, size_t len) const |
| | write an array of bytes to a specific register in the I²C device
|
| |
| bool | write_registers (const I2CRegValue *table, size_t count) const |
| | Write each register and value of table in order, stopping at the first failure.
|
| |
| template<size_t N> |
| bool | write_registers (const I2CRegValue(&table)[N]) const |
| |
| bool | check_chip_id (Component *component, uint8_t a_register, uint8_t expected, uint8_t mask=0xFF) |
| | Read the 8-bit ID at a_register and accept it when it matches expected in the bits set in mask.
|
| |
| bool | read_bytes (uint8_t a_register, uint8_t *data, uint8_t len) |
| | Compat APIs All methods below have been added for compatibility reasons.
|
| |
| bool | read_bytes_raw (uint8_t *data, uint8_t len) const |
| |
| template<size_t N> |
| optional< std::array< uint8_t, N > > | read_bytes (uint8_t a_register) |
| |
| template<size_t N> |
| optional< std::array< uint8_t, N > > | read_bytes_raw () |
| |
| bool | read_bytes_16 (uint8_t a_register, uint16_t *data, uint8_t len) |
| |
| bool | read_byte (uint8_t a_register, uint8_t *data) |
| |
| optional< uint8_t > | read_byte (uint8_t a_register) |
| |
| bool | read_byte_16 (uint8_t a_register, uint16_t *data) |
| |
| bool | read_bytes_16_le (uint8_t a_register, uint16_t *data, uint8_t len) |
| | Read len 16-bit values stored least significant byte first; no conversion is compiled on little-endian hosts.
|
| |
| bool | read_bytes_16_le (uint8_t a_register, int16_t *data, uint8_t len) |
| |
| bool | read_byte_16_le (uint8_t a_register, uint16_t *data) |
| | Read a 16-bit value stored least significant byte first.
|
| |
| bool | write_bytes (uint8_t a_register, const uint8_t *data, uint8_t len) const |
| |
| bool | write_bytes (uint8_t a_register, const std::vector< uint8_t > &data) const |
| |
| template<size_t N> |
| bool | write_bytes (uint8_t a_register, const std::array< uint8_t, N > &data) |
| |
| bool | write_bytes_16 (uint8_t a_register, const uint16_t *data, uint8_t len) const |
| |
| bool | write_byte (uint8_t a_register, uint8_t data) const |
| |
| bool | write_byte_16 (uint8_t a_register, uint16_t data) const |
| |
| bool | write_byte_16_le (uint8_t a_register, uint16_t data) const |
| | Write a 16-bit value least significant byte first.
|
| |
| bool | update_register (uint8_t a_register, uint8_t mask, uint8_t value) |
| | Read a register, replace the bits in mask with those of value and write it back.
|
| |
| | PollingComponent () |
| |
| | PollingComponent (uint32_t update_interval) |
| | Initialize this polling component with the given update interval in ms.
|
| |
| void | set_update_interval (uint32_t update_interval) |
| | Manually set the update interval in ms for this polling object.
|
| |
| void | call_setup () override |
| |
| virtual uint32_t | get_update_interval () const |
| | Get the update interval in ms of this sensor.
|
| |
| void | start_poller () |
| |
| void | stop_poller () |
| |
| virtual void | loop () |
| | This method will be called repeatedly.
|
| |
| virtual float | get_setup_priority () const |
| | priority of setup().
|
| |
| float | get_actual_setup_priority () const |
| |
| void | set_setup_priority (float priority) |
| |
| void | call () |
| |
| virtual void | on_shutdown () |
| |
| virtual void | on_safe_shutdown () |
| |
| virtual bool | teardown () |
| | Called during teardown to allow component to gracefully finish operations.
|
| |
| virtual void | on_powerdown () |
| | Called last before a reboot or deep sleep to power down hardware.
|
| |
| uint8_t | get_component_state () const |
| |
| void | reset_to_construction_state () |
| | Reset this component back to the construction state to allow setup to run again.
|
| |
| bool | is_in_loop_state () const |
| | Check if this component has completed setup and is in the loop state.
|
| |
| bool | is_idle () const |
| | Check if this component is idle.
|
| |
| void | mark_failed () |
| | Mark this component as failed.
|
| |
| void | mark_failed (const LogString *message) |
| |
| bool ESPHOME_ALWAYS_INLINE | setup_check (bool ok) |
| | Marks the component failed with message (default "Communication failed") unless ok; returns ok.
|
| |
| bool ESPHOME_ALWAYS_INLINE | setup_check (bool ok, const LogString *message) |
| |
| void | disable_loop () |
| | Disable this component's loop.
|
| |
| void | enable_loop () |
| | Enable this component's loop.
|
| |
| void | enable_loop_soon_any_context () |
| | Thread and ISR-safe version of enable_loop() that can be called from any context.
|
| |
| bool | is_failed () const |
| |
| bool | is_ready () const |
| |
| virtual bool | can_proceed () |
| |
| bool | status_has_warning () const |
| |
| bool | status_has_error () const |
| |
| void | status_set_warning () |
| |
| void | status_set_warning (const char *message) |
| |
| void | status_set_warning (const LogString *message) |
| |
| bool | status_comm_result (bool ok) |
| | Clears the warning when ok, else sets it with message (default "Communication failed"); returns ok.
|
| |
| bool | status_comm_result (bool ok, const LogString *message) |
| |
| void | status_set_error () |
| |
| void | status_set_error (const LogString *message) |
| |
| void | status_clear_warning () |
| |
| void | status_clear_error () |
| |
| | ESPDEPRECATED ("Use status_momentary_warning() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_warning(const char *name |
| |
| void | status_momentary_warning (uint32_t length=5000) |
| | Set warning status flag and clear it after length ms.
|
| |
| void | status_momentary_warning (const LogString *message, uint32_t length=5000) |
| |
| | ESPDEPRECATED ("Use status_momentary_error() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_error(const char *name |
| |
| void | status_momentary_error (uint32_t length=5000) |
| | Set error status flag and clear it after length ms.
|
| |
| void | status_momentary_error (const LogString *message, uint32_t length=5000) |
| |
| bool | has_overridden_loop () const |
| |
| const LogString * | get_component_log_str () const ESPHOME_ALWAYS_INLINE |
| | Get the integration where this component was declared as a LogString for logging.
|
| |
| bool | should_warn_of_blocking (uint32_t blocking_time, uint32_t &threshold_ms_out) |
| |
|
| template<typename T > |
| bool | read_reg_ (uint8_t reg, T *value) |
| |
| template<typename T > |
| bool | write_reg_ (uint8_t reg, const T &value) |
| |
| bool | write_command_raw_ (float value) |
| |
| bool | write_direction_raw_ (Direction direction) |
| |
| bool | read_command_raw_ (float *value) |
| |
| void | finish_direction_change_ () |
| |
| friend | void::setup () |
| |
| friend | void::original_setup () |
| |
| void | set_component_source_ (uint8_t index) |
| | Set where this component was loaded from for some debug messages.
|
| |
| void | call_dump_config_ () |
| |
| void | enable_loop_slow_path_ () |
| |
| void | set_component_state_ (uint8_t state) |
| | Helper to set component state (clears state bits and sets new state)
|
| |
| bool | set_status_flag_ (uint8_t flag) |
| | Helper to set a status LED flag on both this component and the app.
|
| |
| bool | set_error_flag_ (const LogString *message) |
| | Set the error flag and log it; true when it was not set before.
|
| |
| void | set_interval (const char *name, uint32_t interval, std::function< void()> &&f) |
| | Set an interval function with a const char* name.
|
| |
| void | set_interval (uint32_t id, uint32_t interval, std::function< void()> &&f) |
| | Set an interval function with a numeric ID (zero heap allocation).
|
| |
| void | set_interval (InternalSchedulerID id, uint32_t interval, std::function< void()> &&f) |
| |
| void | set_interval (uint32_t interval, std::function< void()> &&f) |
| |
| bool | cancel_interval (const char *name) |
| | Cancel an interval function.
|
| |
| bool | cancel_interval (uint32_t id) |
| |
| bool | cancel_interval (InternalSchedulerID id) |
| |
| void | set_timeout (const char *name, uint32_t timeout, std::function< void()> &&f) |
| | Set a timeout function with a const char* name.
|
| |
| void | set_timeout (uint32_t id, uint32_t timeout, std::function< void()> &&f) |
| | Set a timeout function with a numeric ID (zero heap allocation).
|
| |
| void | set_timeout (InternalSchedulerID id, uint32_t timeout, std::function< void()> &&f) |
| |
| void | set_timeout (uint32_t timeout, std::function< void()> &&f) |
| |
| bool | cancel_timeout (const char *name) |
| | Cancel a timeout function.
|
| |
| bool | cancel_timeout (uint32_t id) |
| |
| bool | cancel_timeout (InternalSchedulerID id) |
| |
| void | defer (const char *name, std::function< void()> &&f) |
| | Defer a callback to the next loop() call with a const char* name.
|
| |
| void | defer (std::function< void()> &&f) |
| | Defer a callback to the next loop() call.
|
| |
| void | defer (uint32_t id, std::function< void()> &&f) |
| | Defer a callback with a numeric ID (zero heap allocation)
|
| |
| bool | cancel_defer (const char *name) |
| | Cancel a defer callback using the specified name, name must not be empty.
|
| |
| bool | cancel_defer (uint32_t id) |
| |
| void | status_clear_warning_slow_path_ () |
| |
| void | status_clear_error_slow_path_ () |
| |
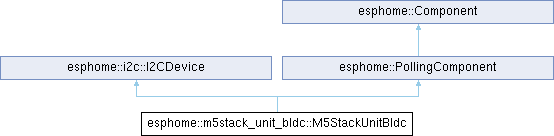
Hub for one M5Stack M5Unit-BLDC brushless motor driver.
Definition at line 43 of file m5stack_unit_bldc.h.
 Public Member Functions inherited from esphome::i2c::I2CDevice
 1.12.0